BUILD GUIDES
Turn the parts you buy into a robot system you can verify.
From unboxing and wiring to firmware and acceptance, every guide connects to the parts required for the work.
2D LiDAR SLAM: A Controlled slam_toolbox Mapping Baseline
Build a repeatable small-area map only after the MS200 or RPLIDAR C1 scan, motion feedback and TF chain have passed acceptance.
URDF and TF: Frames for a Tracked Base, LiDAR and RGB-D Camera
Create a measured, inspectable frame tree for the base, MS200 LiDAR and Aurora930 Pro camera before mapping or perception.
Cogalloy T1 Advanced: Repeatable Navigation-Base Acceptance
Use a gated acceptance sequence for power, motion, odometry, LiDAR frames, mapping and supervised navigation on the tracked platform.
Cogalloy T1 Advanced: Safe cmd_vel and Differential-Drive Acceptance
Validate supervised low-speed cmd_vel behavior on the tracked base after power, controller and encoder directions are known.
Cogalloy Pro: Host Audio and Safe Robot-Voice Interaction
Integrate the USB voice front end with a host application while keeping recognition, robot behavior and motion safety separate.
Cogalloy L1 6-DOF Arm: Safe Motion Planning and Bench Acceptance
Establish a measured arm model, protected servo rail and conservative motion limits before using MoveIt 2 planning on the 6-DOF module.
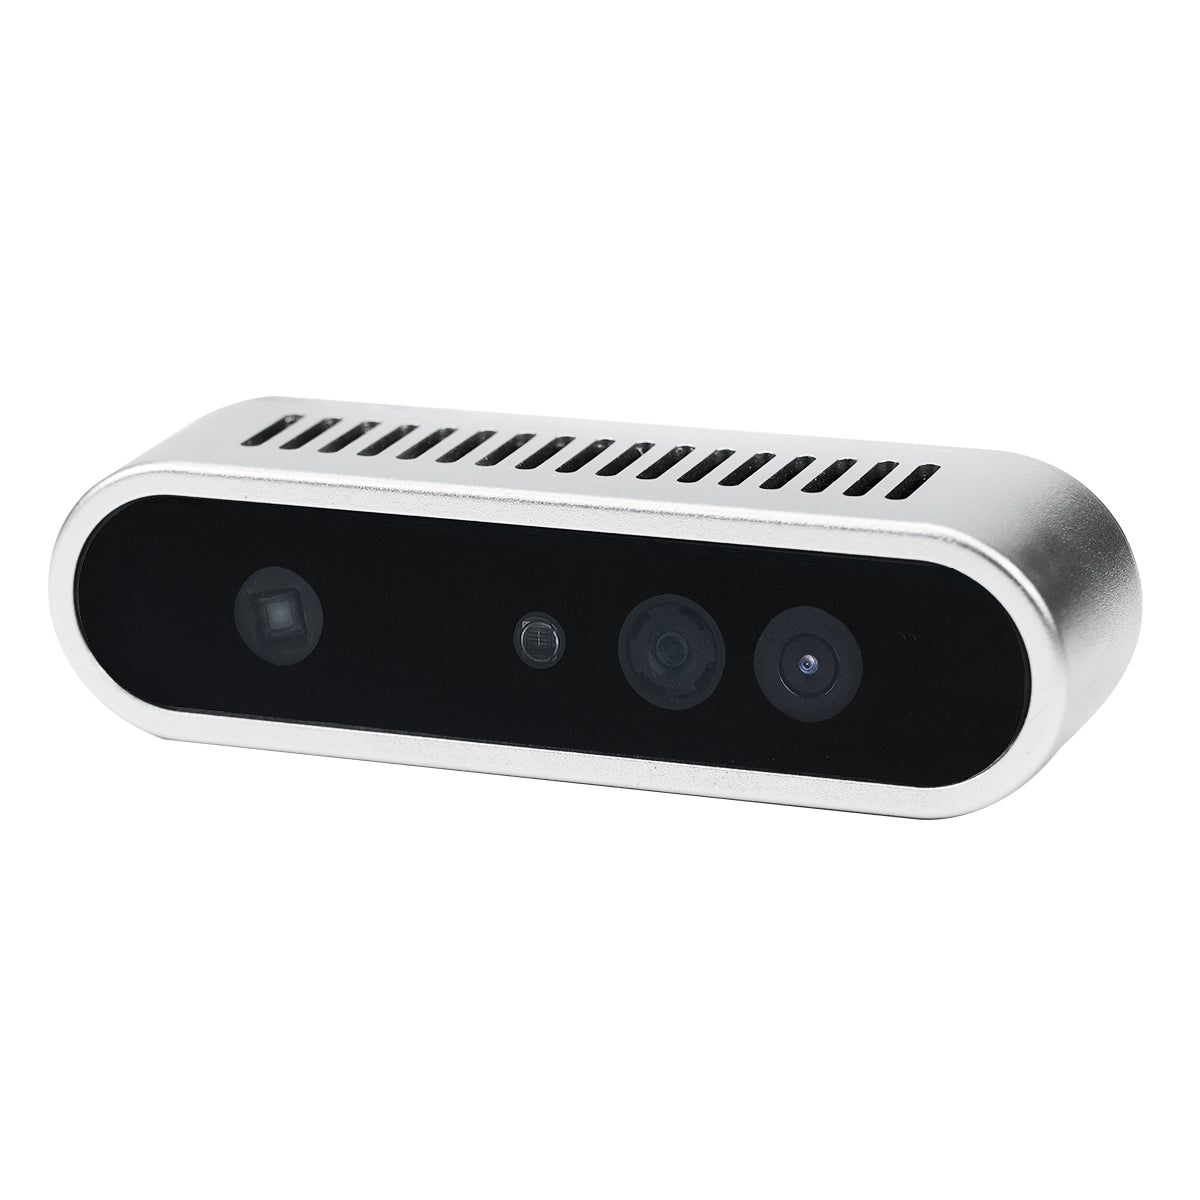
Aurora930 Pro: RGB-D Bring-Up and ROS 2 / OpenCV Validation
Validate aligned depth, RGB and IR streams from the Aurora930 Pro before using the camera for perception decisions.
Nav2 on a Tracked Robot: Map-to-Goal Supervised Validation
Run a conservative Nav2 localization and goal test only after mapping, motion safety and sensor acceptance are repeatable.
MS200 2D LiDAR: UART Bring-Up and Scan Acceptance
Validate the compact MS200 LiDAR power path, delivered 4-pin UART pinout and raw 360° scan before mapping.
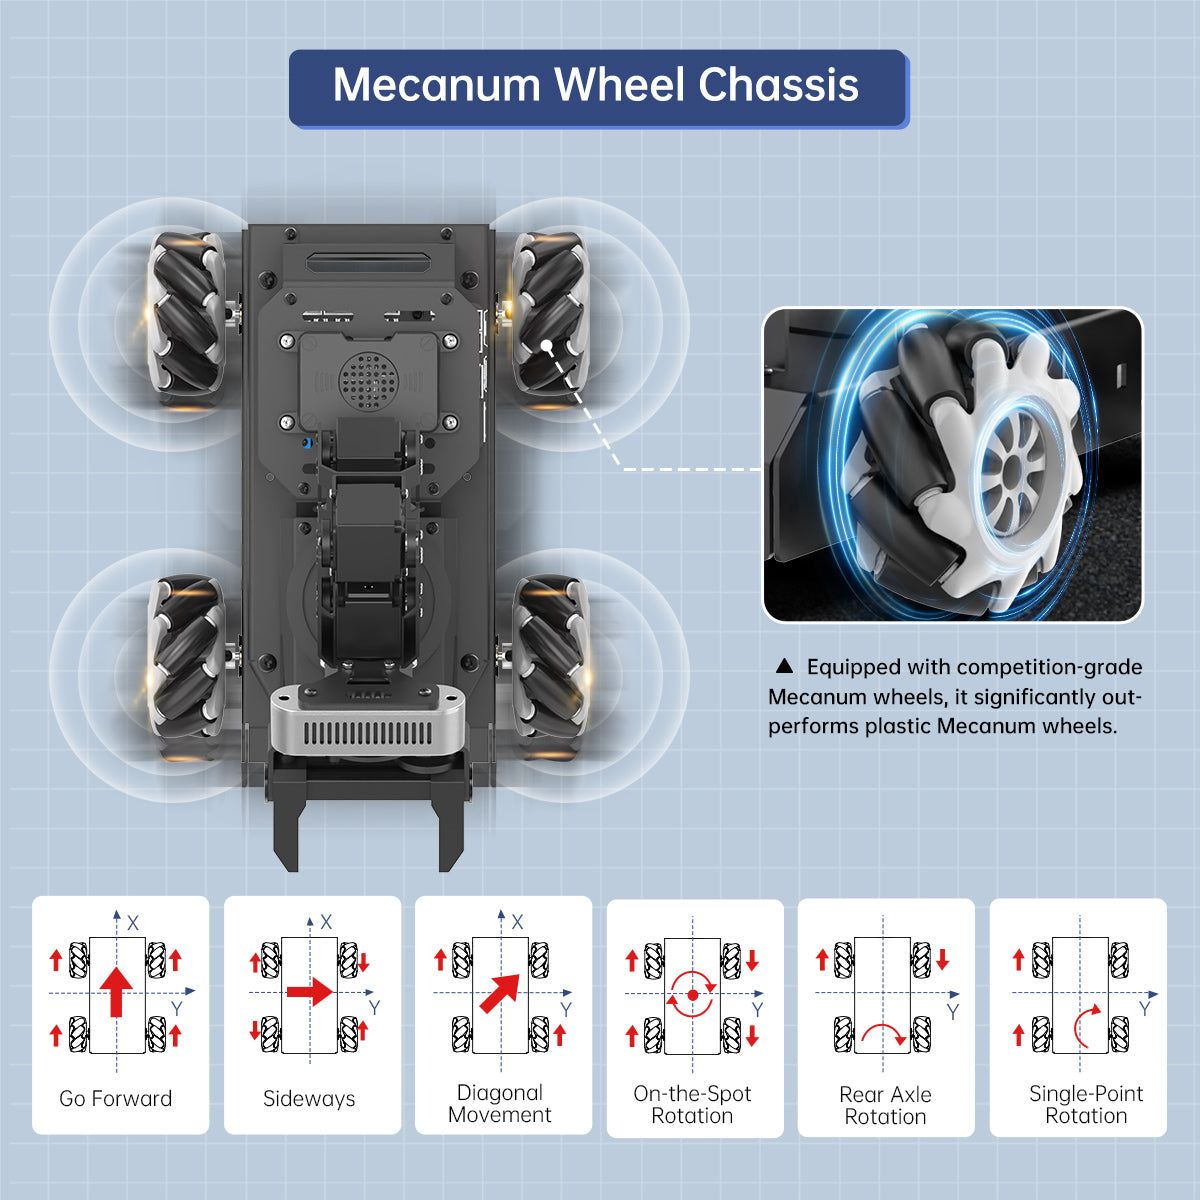
Cogalloy L1 Mecanum: A Safe ros2_control Integration Plan
Plan and validate the hardware interface from host command to encoder feedback without assuming an out-of-box controller plugin.
Cogalloy L1 Mecanum: Encoder and IMU Odometry Baseline
Calibrate encoder and IMU conventions for a four-wheel Mecanum base before trusting odometry for mapping or autonomous motion.
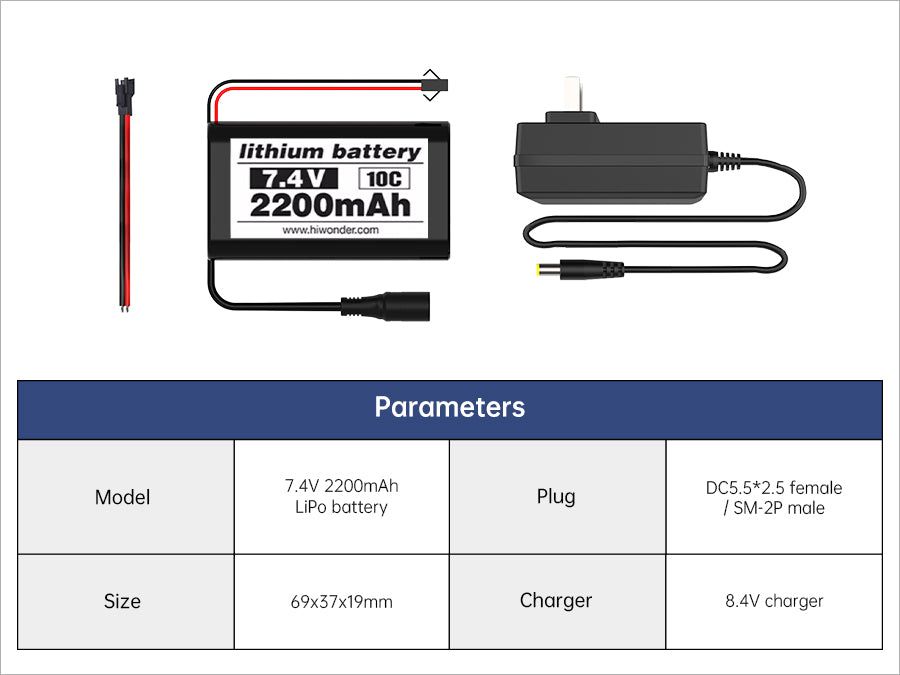
7.4 V 2200 mAh Battery Pack: Compatibility and Preflight
Confirm voltage, connectors, polarity and charge path before a 7.4 V battery pack becomes part of a robot power design.
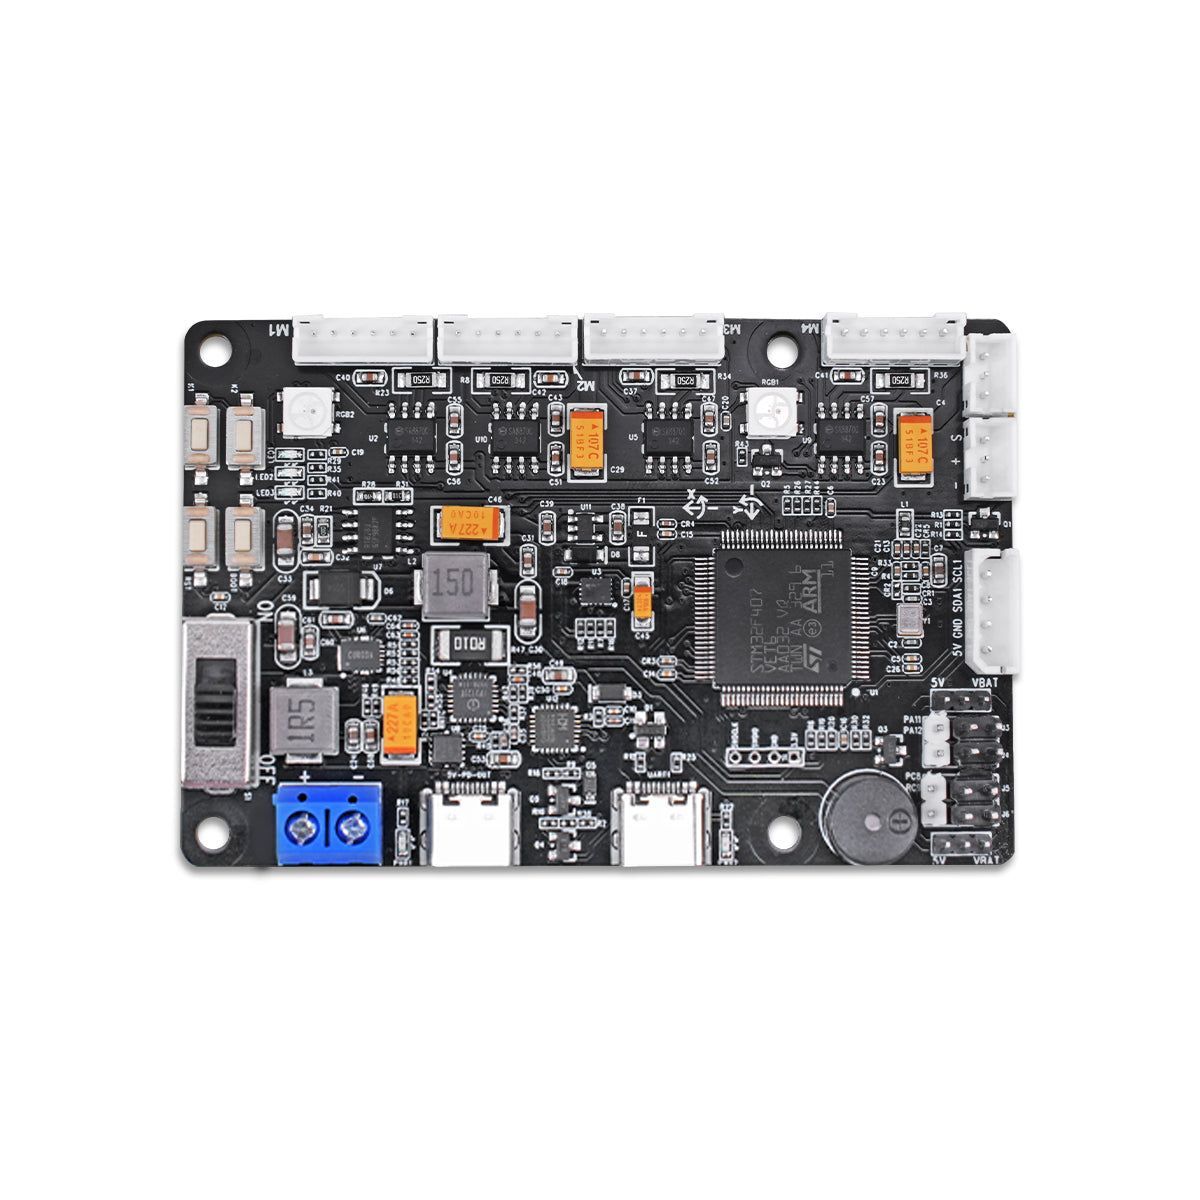
RRC Lite Commissioning: Power, USB Link and Safe I/O Checks
Commission the STM32 controller, Raspberry Pi 5 power path and read-only I/O before enabling any motor channel.
Raspberry Pi 5 + RRC Lite: Your First ROS 2 Telemetry Node
Create a safe ROS 2 Python telemetry node before translating any serial data into motor or servo commands.
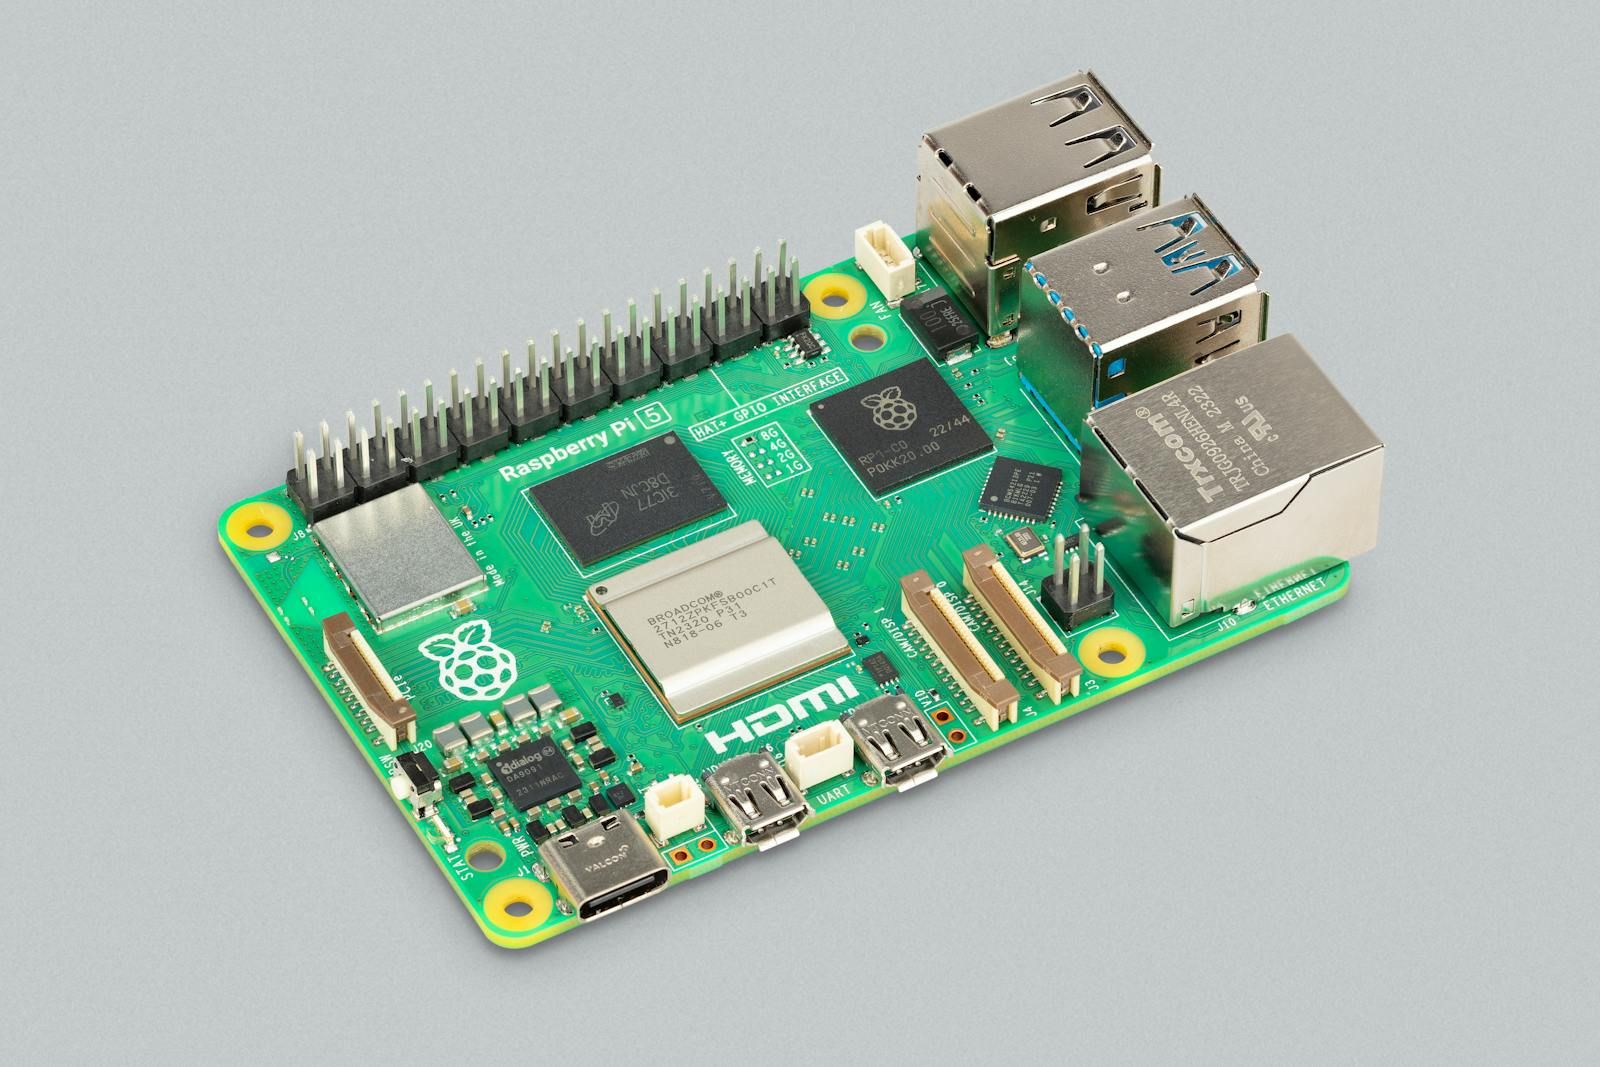
Raspberry Pi 5: ROS 2 Jazzy Development Baseline
Build a reproducible Ubuntu 24.04 and ROS 2 Jazzy baseline on a Raspberry Pi 5 8 GB before connecting robot hardware.
Cogalloy T1 Advanced: Delivery, Power and Wiring Inspection
Inspect the delivered tracked chassis, its included 11.1 V battery system and all expansion wiring before the first powered test.
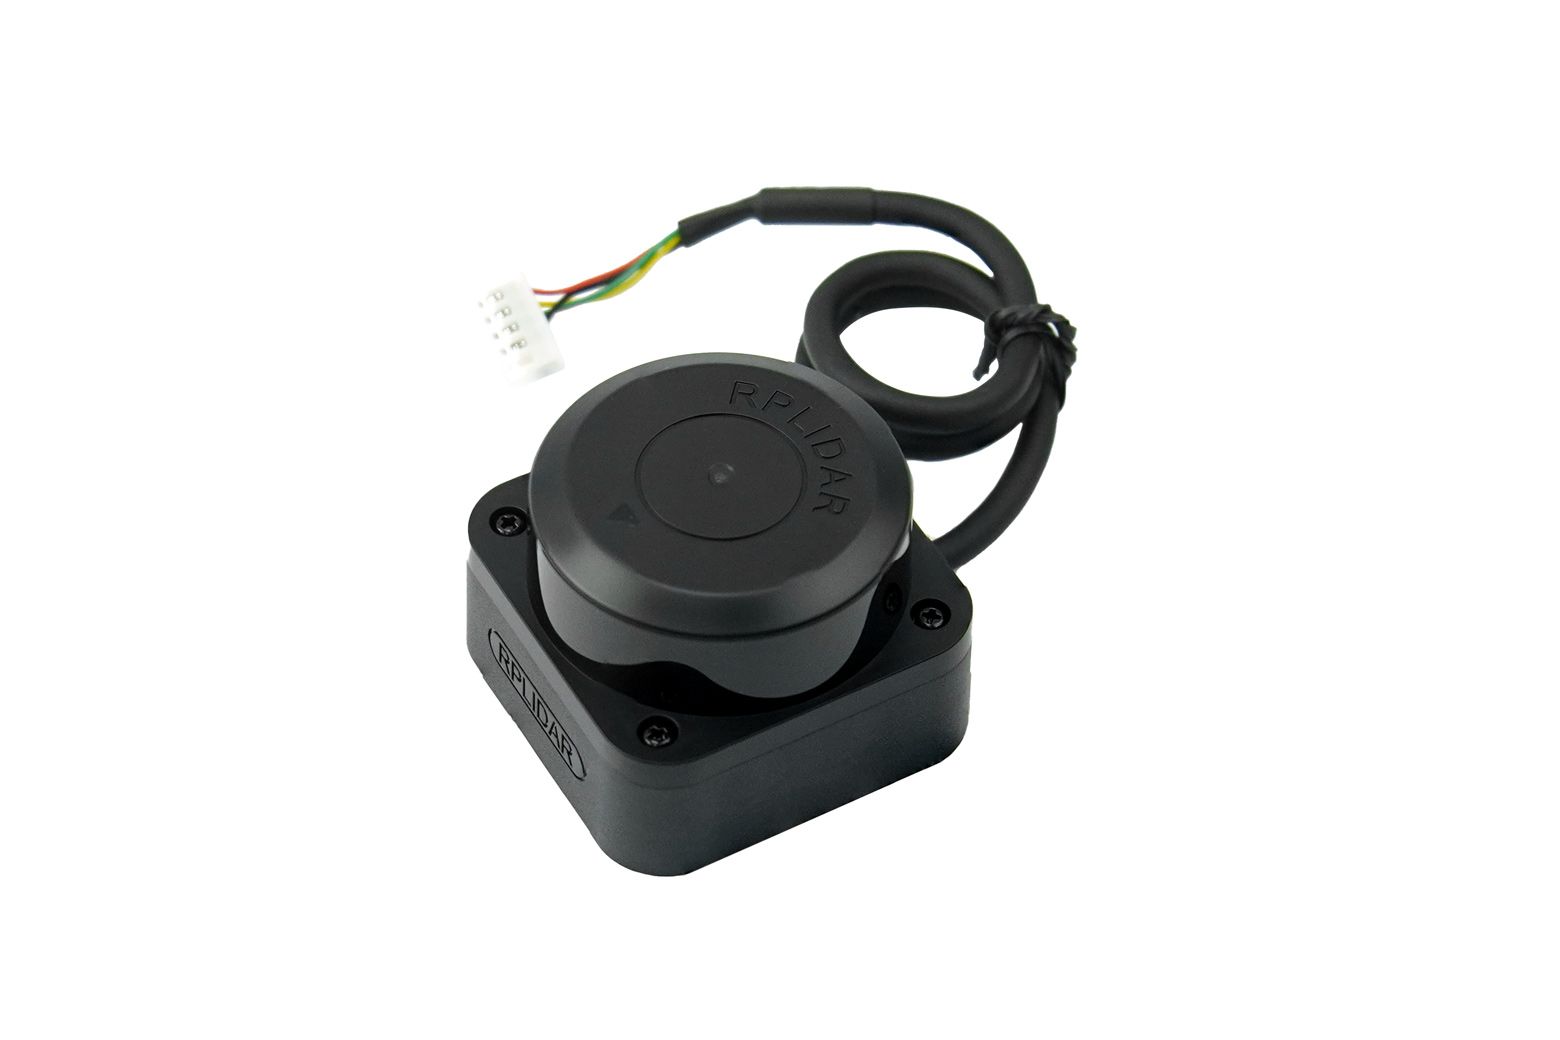
RPLIDAR C1: LaserScan Bring-Up and Acceptance
Bring up the RPLIDAR C1 with its verified power, TTL UART and frame convention before it is used for SLAM or obstacle decisions.