Navigation kitKIT-01
T1 Advanced tracked navigation kit
A Raspberry Pi 5 ROS 2 tracked platform with RGB-D vision and 2D LiDAR for mapping, navigation, and acceptance work.
View details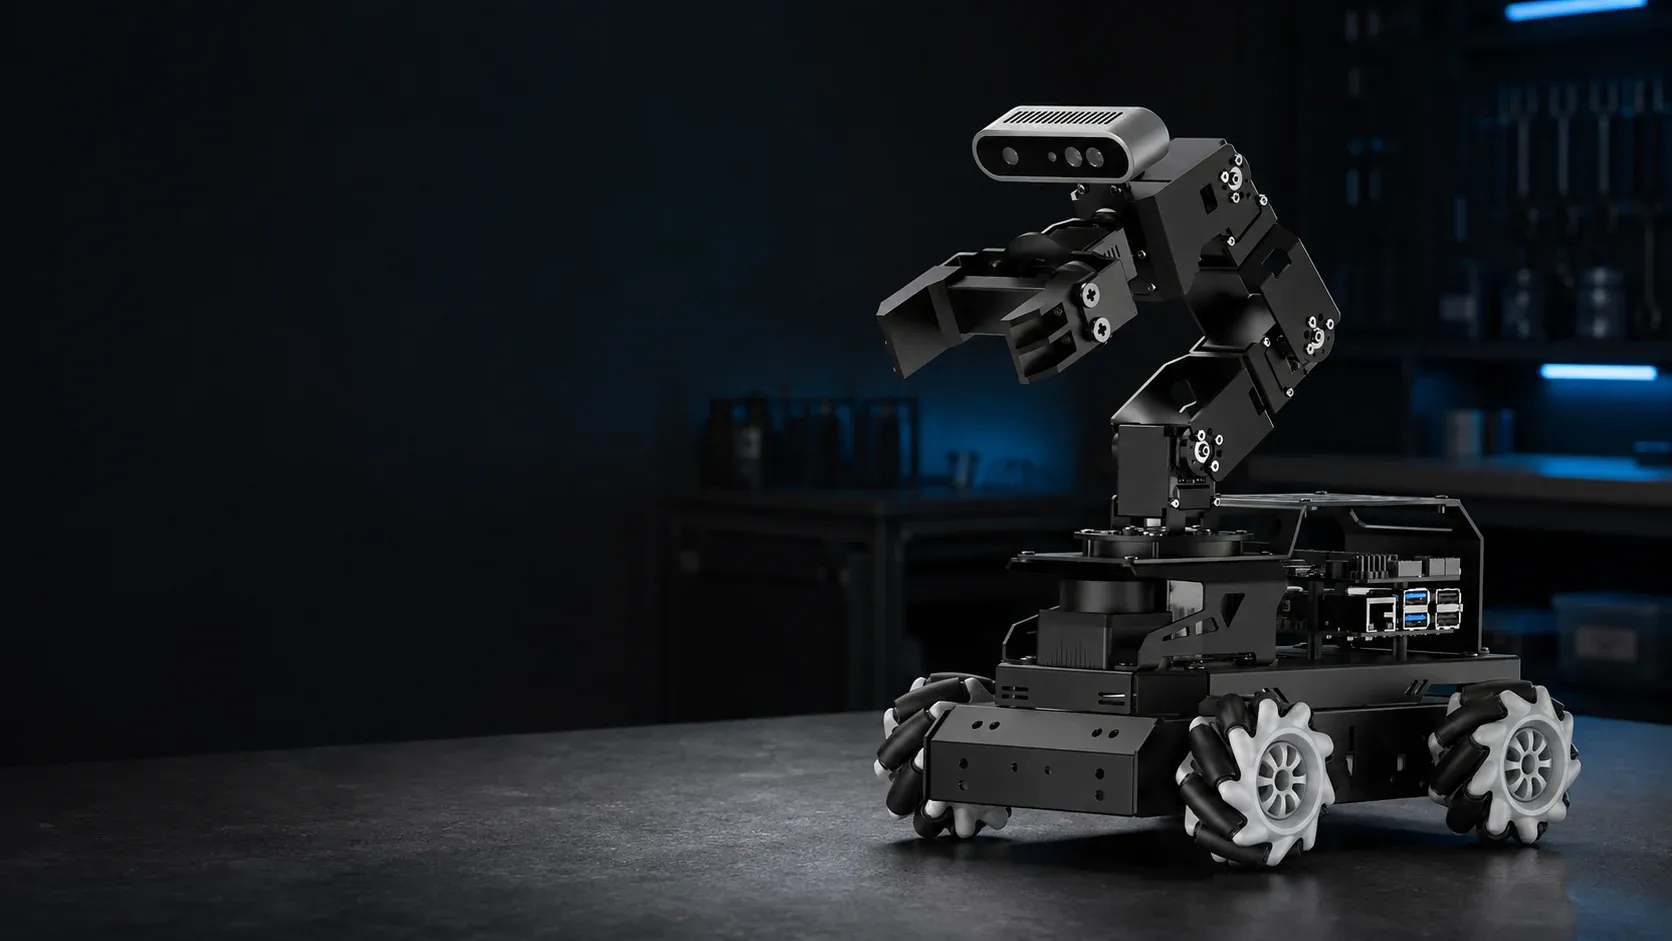
ROBOTICS PARTS WORKBENCH
Match every critical part for the next robot you build.
Browse by sensing, motion, control, structure, and power so every purchase starts from real interfaces and build goals.
Move freely. Reach precisely.
Mecanum mobility, a 6-DOF arm and depth perception in one ROS 2 platform.
Explore L1 AdvancedSHOP BY SUBSYSTEM
Every category is organized around interfaces, mounting, and working relationships, not isolated SKU lists.
LiDAR, cameras, and spatial sensing
Browse partsRobot arms, motors, servos, and end effectors
Browse partsCompute modules, motion drivers, and I/O
Browse partsMobile bases, frames, wheels, and mechanical foundations
Browse partsBattery packs, regulation, protection, and wiring
Browse partsMulti-port controllers, adapters, mounts, and build accessories
Browse partsSYSTEM STARTING POINTS
Each starting point is a purchasable kit or core module. Open it to review its specifications, price, and the compatible parts you can add next.
A Raspberry Pi 5 ROS 2 tracked platform with RGB-D vision and 2D LiDAR for mapping, navigation, and acceptance work.
View detailsAn RGB-D depth camera for ROS 2 vision, spatial sensing, and a debuggable perception stack.
View detailsAn omnidirectional ROS 2 platform combining mecanum drive, an arm, vision, and control for prototype work.
View detailsSELECTED CATALOGUE
Compare key specifications, compatibility, and pricing, then add available parts directly to your cart.
A pre-assembled, double-layer suspension tracked mobile base for custom ROS 2 and autonomous...
An 8 GB Raspberry Pi 5 Model B bare board for Linux, ROS 2, sensing and robot applications....
A real-time STM32F407VET6 control layer for Raspberry Pi 5 robots: four independent encoder-...
Compact structured-light RGB-D camera for ROS 2 robots needing local 3D perception: aligned...
BUILD GUIDES
Use wiring, configuration, and acceptance steps to remove uncertainty after purchase.
Read guideJOURNAL
A staged selection and acceptance case for a compact indoor Mecanum platform with a 6-DOF arm, RGB-D perception and ROS 2 host.
Read articleSelection & Case Study
02A reference architecture for a stationary or supervised robot that combines voice interaction, local RGB-D per...
Selection & Case Study
03A practical reference architecture for an indoor teaching, prototype, or light-inspection robot: what to selec...
Selection & Case Study
04Use a concrete interface matrix to select host compute, real-time control, sensors and actuators before commit...
Selection & Case Study
05A power-selection case that separates energy, peak current, connector compatibility and regulated rails before...