COGALLOY JOURNAL
Turn selection experience into the method behind the next build.
Part notes on interfaces, power, mounting, and verification for clearer purchasing and integration decisions.
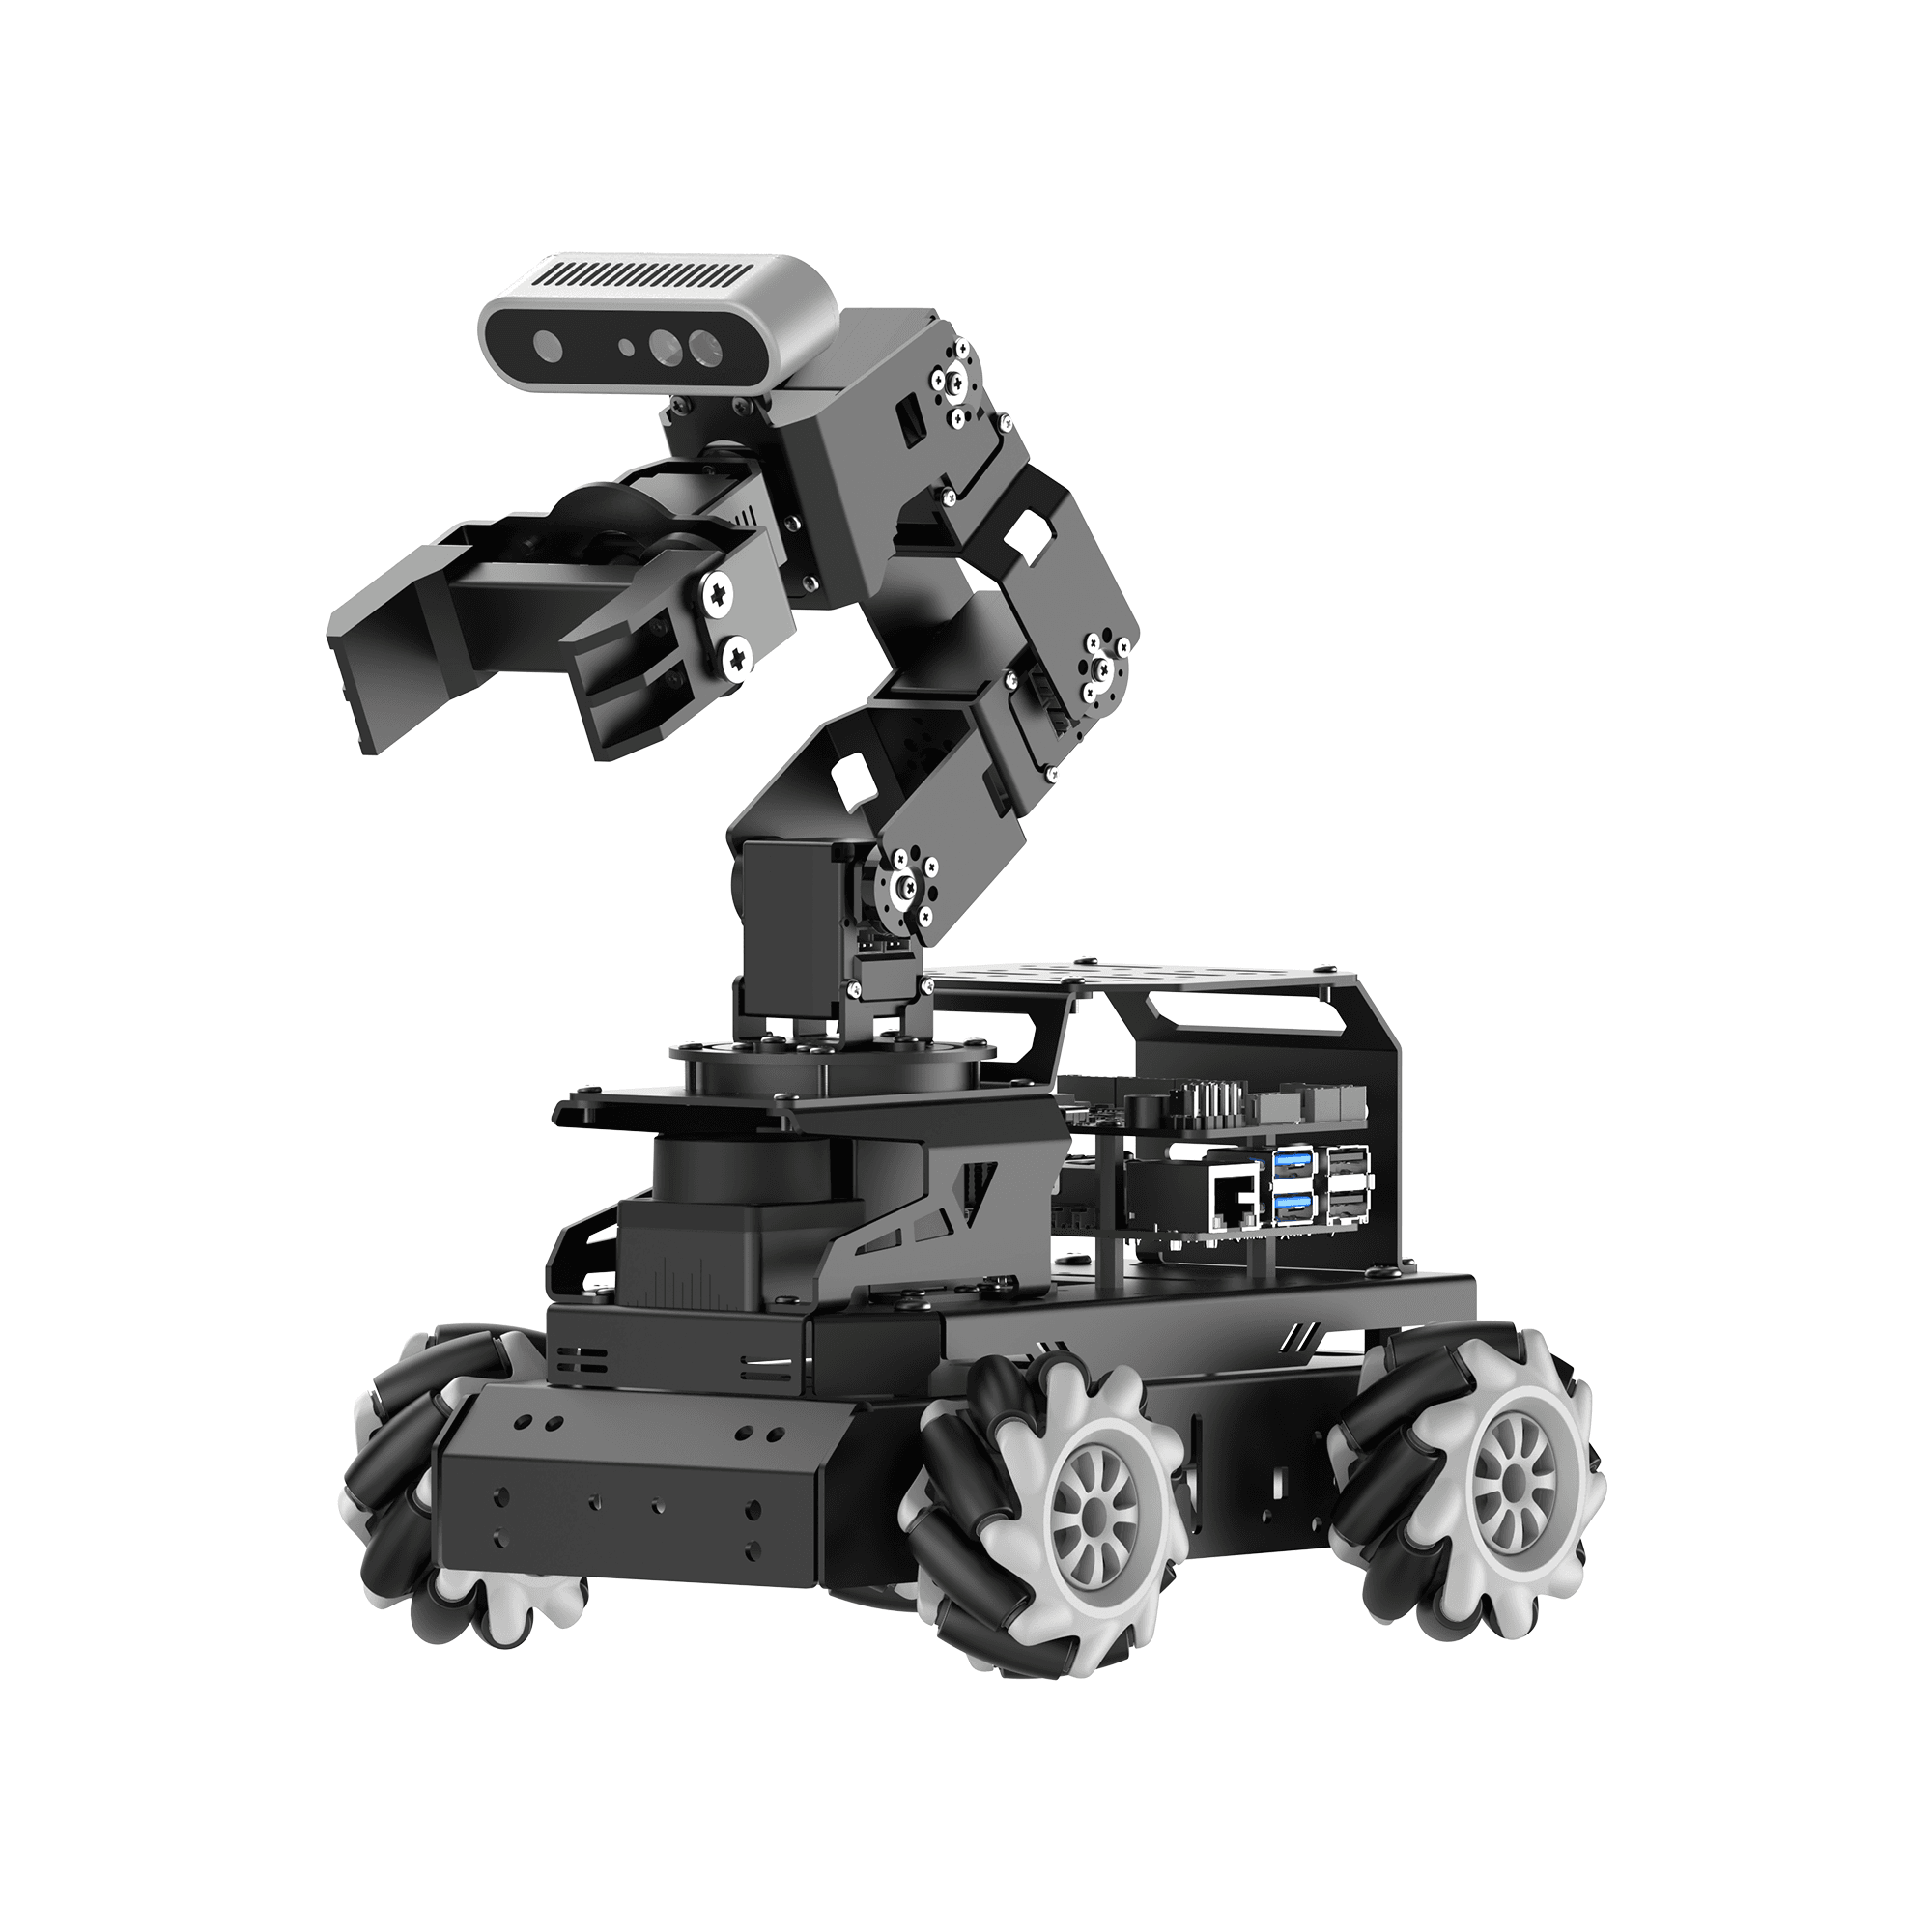
Selection & Case Study
Selection case: a compact Mecanum mobile-manipulation baseline
A staged selection and acceptance case for a compact indoor Mecanum platform with a 6-DOF arm, RGB-D perception and ROS 2 host.
Selection & Case Study
Selection case: adding voice and RGB-D interaction without weakening safety
A reference architecture for a stationary or supervised robot that combines voice interaction, local RGB-D perception and a host-controlled action workflow.
Read article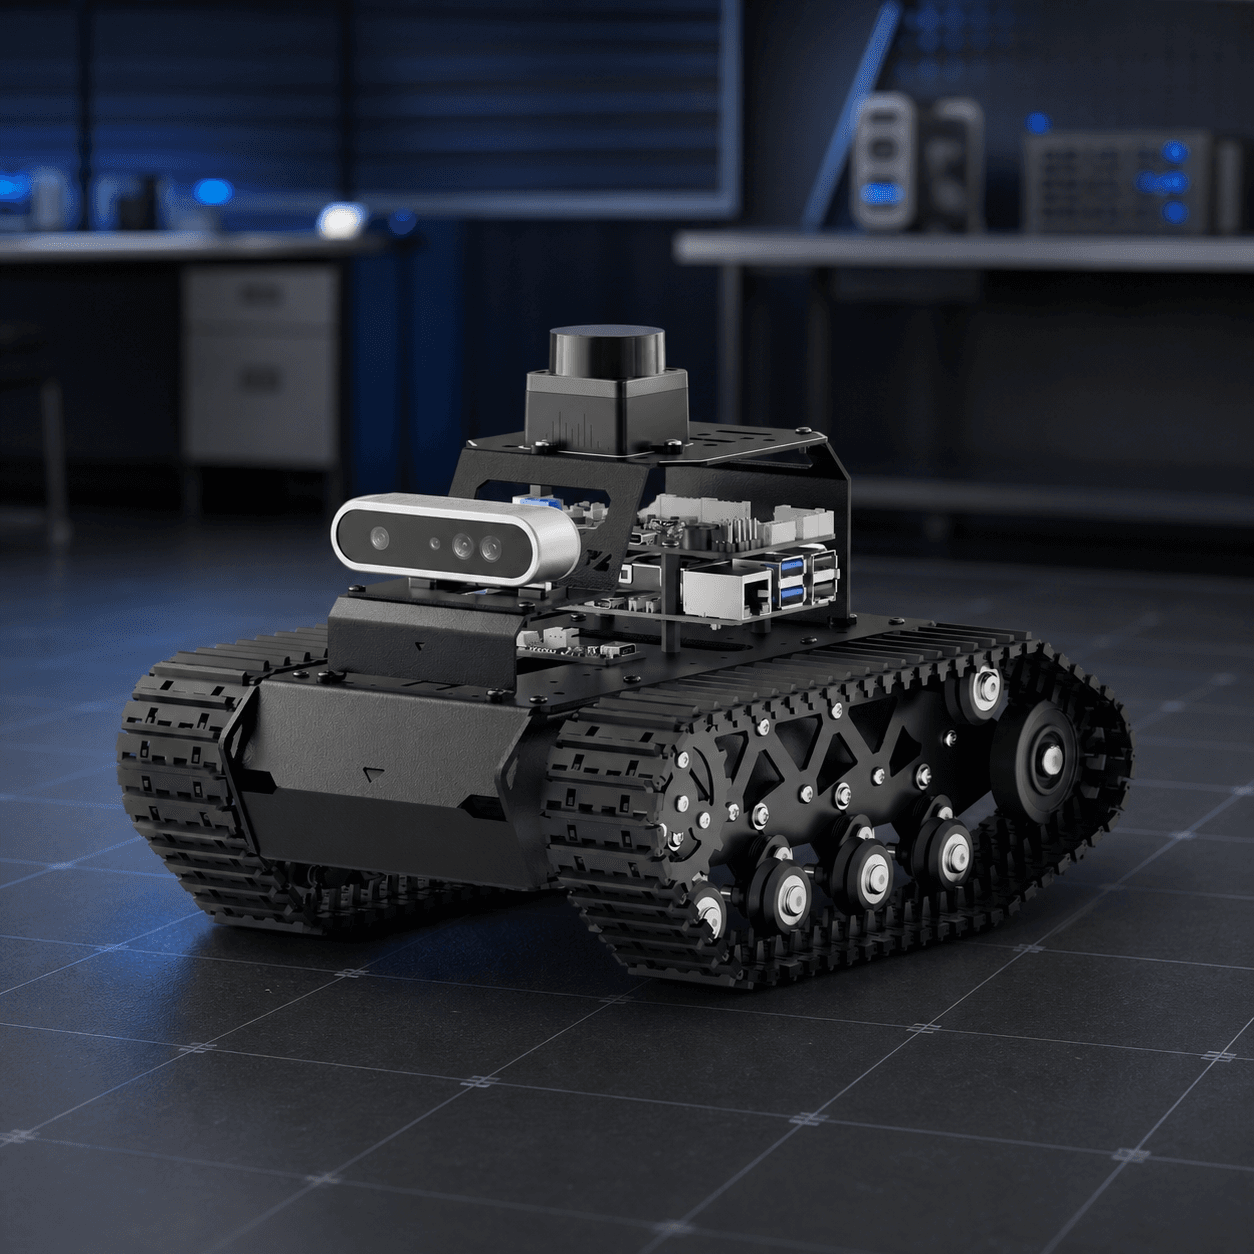
Selection & Case Study
Selection Case: Building an Indoor ROS 2 Navigation Robot with MS200 and Cogalloy T1 Advanced
A practical reference architecture for an indoor teaching, prototype, or light-inspection robot: what to select, why the components fit together, how to integrate them, and which checks must pass before navigation is allowed to move the chassis.
Read article
Selection & Case Study
Selection case: define interfaces before choosing a controller
Use a concrete interface matrix to select host compute, real-time control, sensors and actuators before committing to a board.
Read article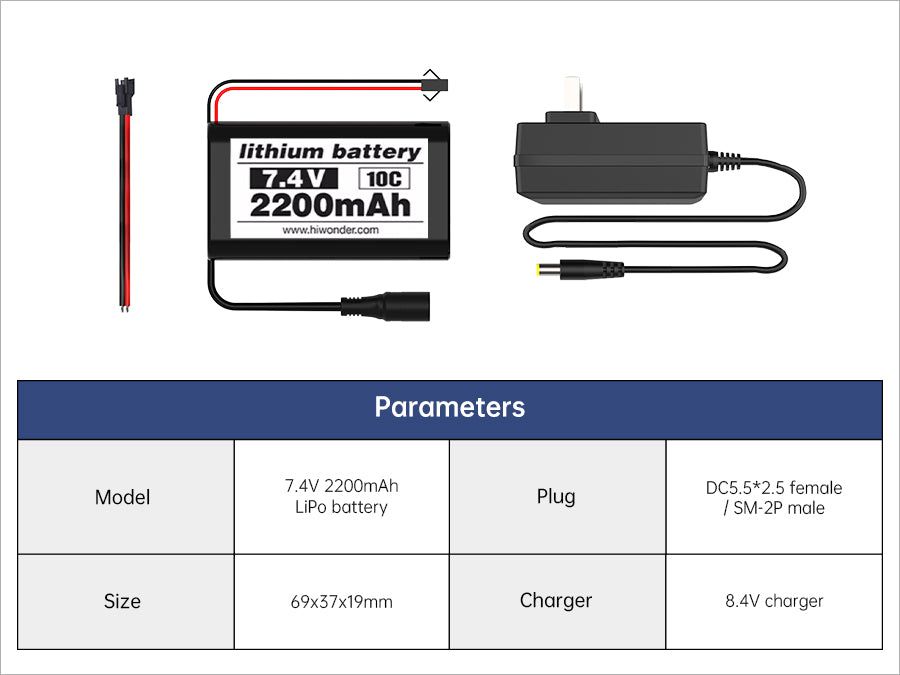
Selection & Case Study
Selection case: a mobile-platform power budget beyond battery capacity
A power-selection case that separates energy, peak current, connector compatibility and regulated rails before a mobile robot is assembled.
Read articleSelection & Case Study
From a part to a repeatable robot build
A practical method for turning a catalogue selection into a build a second engineer can assemble, test, diagnose and extend.
Read article