What this guide proves
A small rclpy package publishes an explicit, non-motion telemetry topic and a second terminal can inspect it. The exercise gives the host software a trustworthy baseline before it touches a controller interface.
Hardware and scope boundary
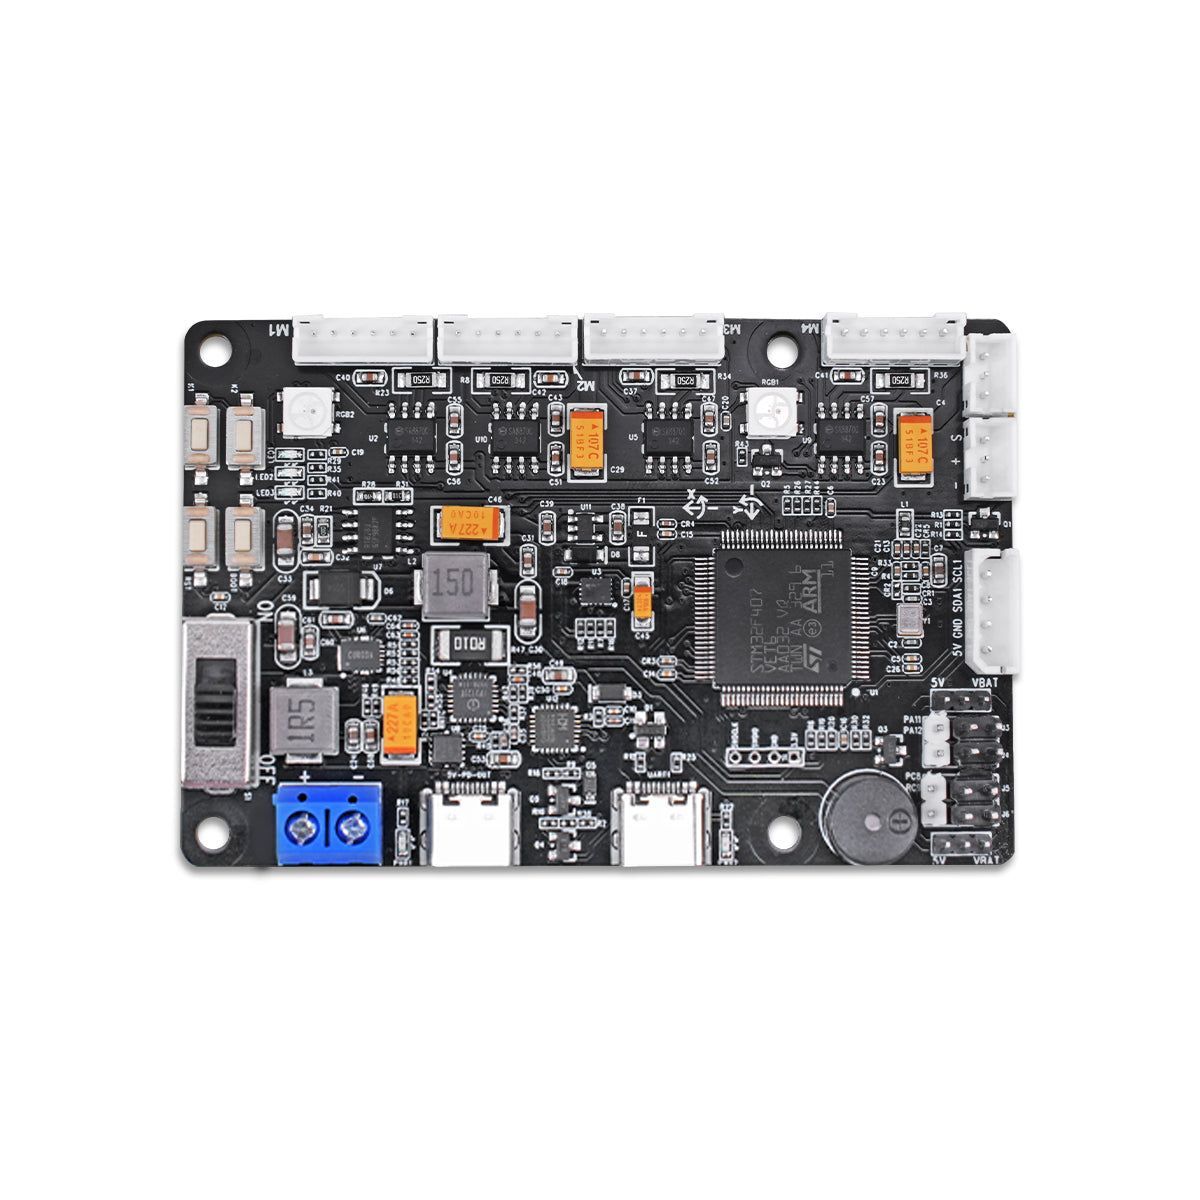
COG-RPI5-8GB runs ROS 2 applications. COG-RRC-LITE is an STM32 real-time controller with encoder-motor channels, IMU and serial I/O. This guide does not assume a particular RRC Lite firmware protocol and never sends a movement command.
Prepare before applying power
Finish the Raspberry Pi 5 ROS 2 baseline first. Keep motors and servos disconnected or mechanically safe. If a Type-C link to the controller is connected, identify it through its stable /dev/serial/by-id path rather than assuming a numbered tty device.
Procedure
- Create an ament_python package in the workspace and add one publisher node plus one subscriber node.
- Publish a simple status message such as build stage, timestamp and a fixed safe value on a clearly named topic such as /robot_build/status.
- Build the package, source the workspace, run the publisher in one terminal and inspect its message rate in another terminal with ros2 topic echo or ros2 topic hz.
- If the delivered controller offers a documented read-only serial status command, capture its version or heartbeat separately and record the serial path and baud rate. Do not infer a command format from another controller.
- Keep controller parsing and command generation as separate nodes or modules. A malformed telemetry packet must never become a velocity, PWM or bus-servo command.
Pass criteria and record
The package builds from a clean workspace, its topic name and rate are documented, and a rebooted Pi can reproduce the result. If a controller link is present, record its verified port and firmware identity without issuing motion.
Do not proceed when
Do not continue if the serial device changes unpredictably, packets are not framed reliably, or the host receives data it cannot identify. Disconnect or use read-only diagnostics until the delivered protocol is confirmed.
Continue from here
Commission COG-RRC-LITE power and communication, then add a narrow, rate-limited bridge from verified controller telemetry into ROS 2.