 1 / 2
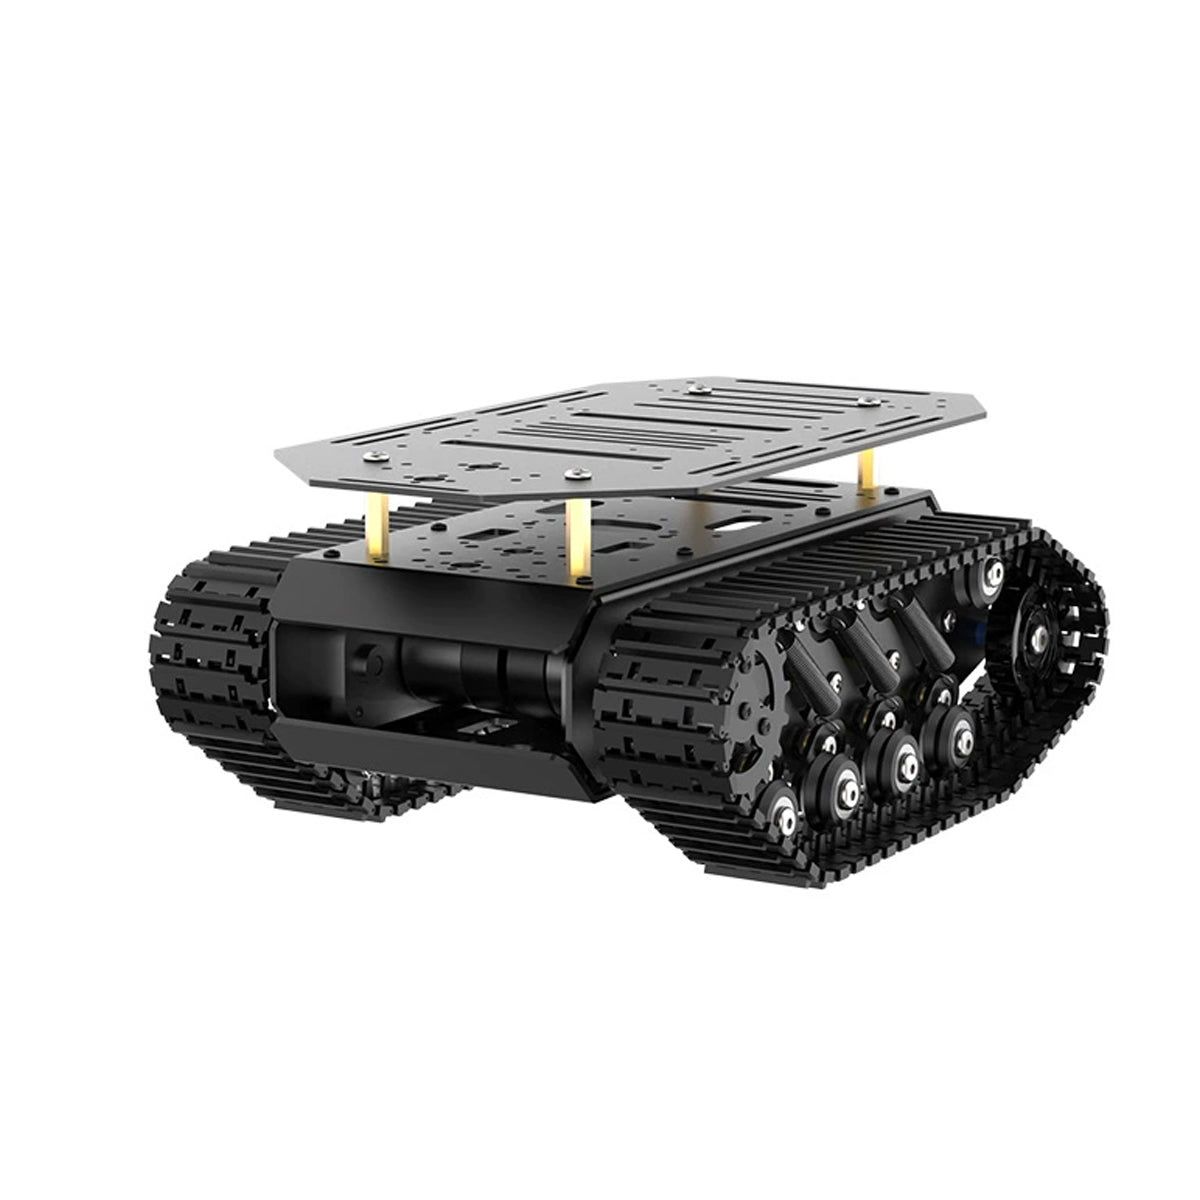
Cogalloy T1 Advanced Suspension Tracked Chassis Kit
A pre-assembled, double-layer suspension tracked mobile base for custom ROS 2 and autonomous-robot builds. This SKU includes two 12 V Hall-encoder gear motors, a 4-channel encoder-motor driver, an 11.1 V / 6000 mAh LiPo pack and a 12.6 V charger; the host computer, sensors and ROS software stack are separate.
- Configured mobile-base kit: Advanced double-layer chassis, encoder-motor driver, 11.1 V battery and charger are defined in one purchasable configuration.
- Suspension tracked motion: Eight tension-spring suspension paths and micro bearings support traction over uneven test surfaces.
- Closed-loop-ready feedback: Two Hall-encoder gear motors give a controller the feedback needed for speed and odometry development.
- Build on your own stack: M3/M4 mounting holes leave the compute, sensing, safety and ROS 2 architecture under your control.
Price
US$119.99
No account or payment needed. We usually confirm availability, lead time, shipping, and total price within 12 hours.
Or email us directly: sales@cogalloy.comShipping options and final delivery cost are shown at checkout.
MOBILE FOUNDATION
A double-layer base that keeps the build boundary clear.
The lower layer is reserved for the supplied battery and the upper deck exposes mounting patterns for your compute and sensing hardware. This SKU is intentionally the mobility layer only, so your host computer and sensor choices remain explicit.
- Assembled advanced double-layer tracked chassis
- M3 and M4 expansion patterns for a custom payload
- Raspberry Pi, Jetson, LiDAR and cameras are separate items
TRACTION AND SUSPENSION
Use the suspension for stability—not as a promise of traction.
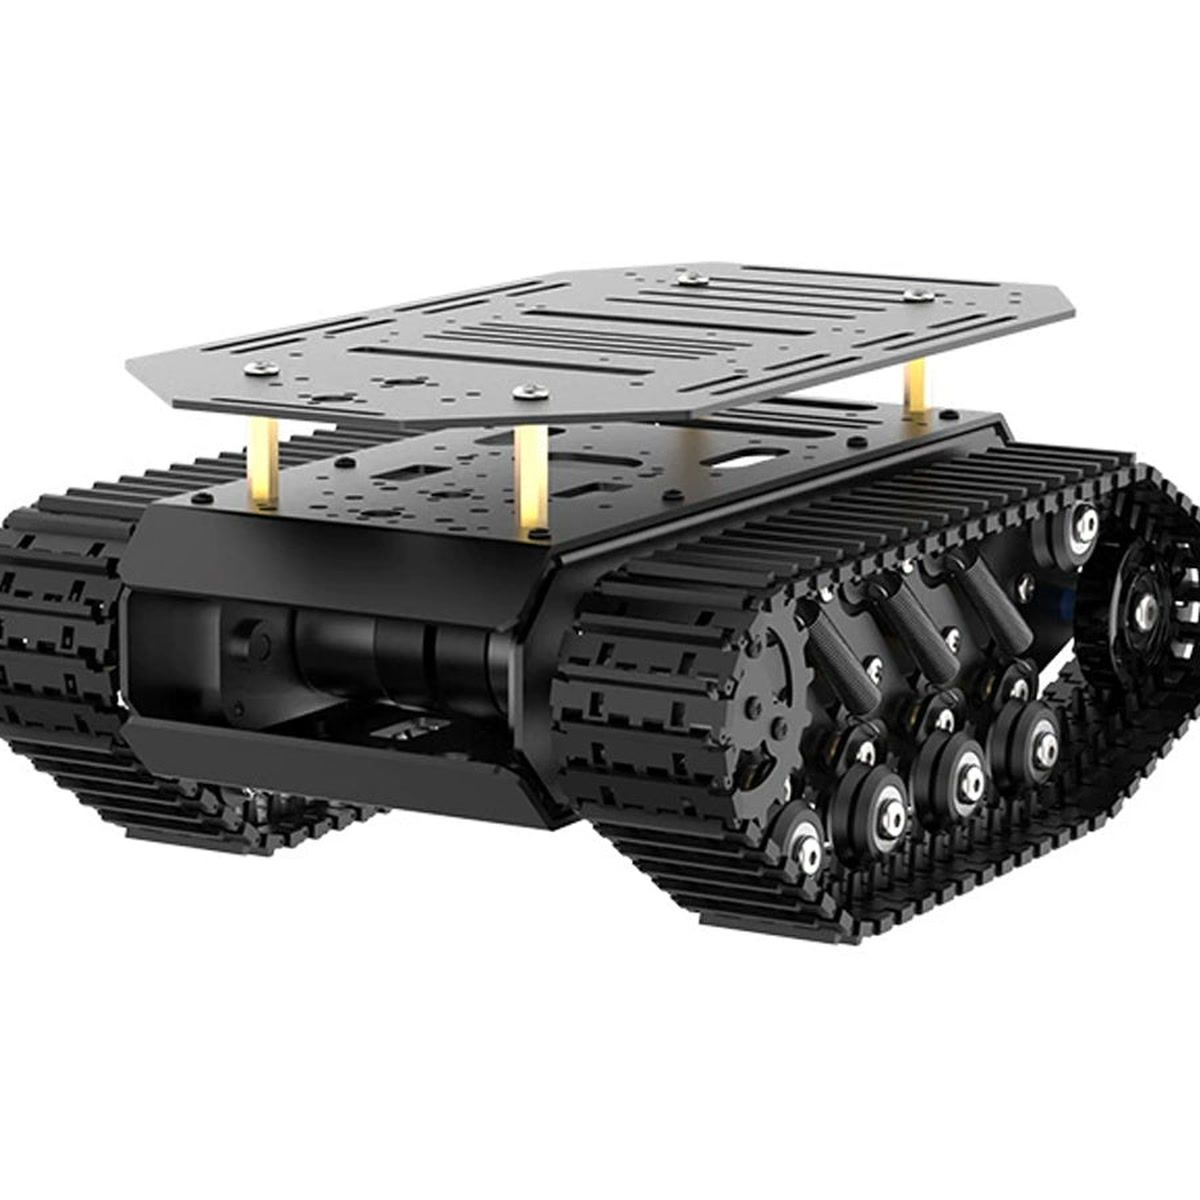
The spring-and-bearing track suspension helps the chassis conform to small surface changes. It does not remove the effects of skid steering, loose surfaces, high center of mass or an improperly secured payload.
- 8-channel carbon-steel tension-spring suspension
- Micro-bearing road-wheel support
- Inspect track tension and hardware before each motion test
MOTION FEEDBACK
Encoder data starts the control loop; calibration finishes it.
The installed Hall-encoder motors and supplied 4-channel driver make feedback-based development possible. Measure real motion on the intended floor after the final payload is installed; tracked odometry drifts when the tracks scrub or slip.
- Two independently driven 12 V Hall-encoder gear motors
- Validate left/right direction before any autonomy test
- Calibrate odometry, velocity limits and stopping behavior in your own controller
POWER AND SAFETY
Keep the battery, host power and motor path separate in your design.
The kit includes an 11.1 V / 6000 mAh lithium battery and 12.6 V charger for the chassis configuration. High-level computing, sensors and their regulated power path are not supplied and must be designed for the installed host.
- Charge only with the supplied / approved 12.6 V charger
- Do not drive the motors from Raspberry Pi GPIO or its 5 V rail
- Provide application-specific emergency stop, fusing and supervision
Related tutorials
Build with your parts
BeginnerCogalloy T1 Advanced: Delivery, Power and Wiring Inspection
Inspect the delivered tracked chassis, its included 11.1 V battery system and all expansion wiring before the first powered test.
Read tutorialIntermediateCogalloy T1 Advanced: Safe cmd_vel and Differential-Drive Acceptance
Validate supervised low-speed cmd_vel behavior on the tracked base after power, controller and encoder directions are known.
Read tutorialAdvancedCogalloy T1 Advanced: Repeatable Navigation-Base Acceptance
Use a gated acceptance sequence for power, motion, odometry, LiDAR frames, mapping and supervised navigation on the tracked platform.
Read tutorialProduct details
Everything you need to evaluate the fit.
Clear product information, technical specifications and compatibility details—kept separate from the purchase decision.
Overview
Selling scope: a mobile base, not a complete robot
COG-T1-TRACK-BASE is the advanced double-layer suspension tracked chassis kit for a Cogalloy T1 Advanced build. It is delivered as an assembled mechanical base with two 12 V Hall-encoder geared motors, a four-channel encoder-motor driver, an 11.1 V / 6000 mAh lithium battery pack and a 12.6 V charger.
It does not include a Raspberry Pi, Jetson, RRC Lite, LiDAR, depth/RGB camera, wireless controller, storage, ROS image, network module, mapping/navigation software, or a complete Cogalloy T1 Advanced robot. Those items must be selected, powered and integrated for the target application.
Mechanical foundation for a custom robot
The two tracks are independently driven, so the base uses differential / skid-steer motion. The double-layer deck gives you a protected lower battery space and an upper mounting surface with M3 and M4 pattern holes. The suspension combines high-elasticity carbon-steel tension springs with micro bearings to help the tracks maintain contact on imperfect indoor surfaces and low obstacles.
The chassis is a mobility platform, not an autonomous system: real-world traction, turning scrub, payload height, cable drag and floor material all affect motion and odometry.
Motor, feedback and power boundary
Each installed JGB3865-520R45-12 brushed gear motor has a Hall encoder and a PH2.0-6P connection. Published references are 12 V nominal operation, a 7–13 V input range, 45:1 reduction, 150 ± 10 rpm post-reduction speed, 0.15 N·m rated torque, 0.5 N·m stall torque and 1.5 A stall current per motor. Treat stall current as a wiring and protection design input, not a normal running-current target.
The supplied 11.1 V battery is inside the stated motor range. Charge it only with the supplied / approved 12.6 V charger, on a non-flammable surface and under supervision. Lithium-battery transport eligibility varies by destination.
Integration checklist before motion
- Mechanically inspect track tension, fasteners, wiring clearance and the battery restraint.
- Confirm the host-to-driver command interface and do not connect the motors directly to Raspberry Pi GPIO.
- Test each side with the robot raised, then verify forward, reverse and turn directions at low speed in a clear area.
- Calibrate encoder polarity, counts and track odometry on the actual floor and payload. Encoder feedback cannot remove track slip.
- Add LiDAR, cameras, ROS 2 navigation and any emergency-stop/safety behavior only after base motion is proven stable.
Purchase boundary
This is the Advanced double-layer + battery + charger configuration. Product photographs show the chassis platform only; installed payloads, host computers, sensors and control hardware are illustrative unless explicitly listed in the packing list.
Technical specifications
Tracks
High-friction molded polymer particle tracks
Battery
11.1 V 6000 mAh lithium battery pack
Charger
12.6 V charger
Encoder
Hall encoder; published reference 11 PPR; validate edge counting in firmware
Gear ratio
45:1
Suspension
8-channel high-elasticity carbon-steel tension-spring suspension with micro bearings
Typical use
Custom mobile robots, ROS 2 base development, perception and navigation integration
Chassis mass
Approx. 1.6 kg for the double-layer chassis (published reference)
Drive layout
Independent left/right tracked drive (differential / skid-steer)
Package mass
Approx. 2.3 kg (published reference)
Rated torque
0.15 N·m per motor (published reference)
Stall torque
0.5 N·m per motor (published reference)
Host computer
Not included
Rated current
0.1 A per motor (published reference)
Stall current
1.5 A per motor (published reference)
Motor connector
PH2.0-6P
Chassis material
Black anodized aluminum alloy
Installed motors
2 × JGB3865-520R45-12 brushed DC geared motors with Hall encoders
Mounting pattern
M3 and M4 expansion holes
Deck construction
Double layer; lower battery space and upper expansion deck
Motor input range
7–13 V DC
Nominal footprint
270 × 194 mm; verify the actual envelope before enclosure design
Ingress protection
No waterproof or outdoor-weather rating is claimed
Post-reduction speed
150 ± 10 rpm (published reference)
Included motor driver
4-channel encoder-motor driver module
Motor nominal voltage
12 V DC
Product configuration
Advanced double-layer suspension tracked chassis kit
Sensors and ROS stack
Not included
Shipping & support
Choose your destination at checkout to see the available shipping methods. Need integration advice before ordering? Our support team can help you choose compatible components.
In the box
Package contents
Advanced double-layer suspension tracked chassis
Pre-assembled black aluminum-alloy mobile base with upper expansion deck.
JGB3865-520R45-12 Hall-encoder DC geared motors
Independent left/right tracked drive motors with PH2.0-6P connections.
4-channel encoder-motor driver module
Low-level motor/encoder interface; it is not a Raspberry Pi, Jetson or complete ROS controller.
11.1 V 6000 mAh lithium battery pack
Included for this advanced battery-and-charger configuration.
12.6 V battery charger
Use only as directed for the supplied battery pack.
Base connection and assembly accessories
Exact accessory count follows the final shipment packing list.
Expert support
Frequently asked questions
Does this SKU include a complete Cogalloy T1 Advanced robot?
No. It is the advanced double-layer mobile-base kit only. Raspberry Pi/Jetson, RRC Lite, LiDAR, camera, storage, wireless controller, ROS image and complete robot integration are not included.
What electronics are included?
The configuration includes the 4-channel encoder-motor driver plus the installed encoder motors. It does not include a high-level computer, ROS controller, network hardware or sensors.
Can I connect the motors directly to a Raspberry Pi?
No. Raspberry Pi GPIO and its 5 V rail must not drive the motors. Use the included compatible motor-driver path, a correctly designed host interface and appropriate power protection.
Are the battery and charger included?
Yes. This SKU is defined as the advanced double-layer configuration with an 11.1 V / 6000 mAh lithium pack and a 12.6 V charger. Battery transport options depend on the destination.
Will encoder feedback make odometry exact?
No. Encoders help estimate motion, but tracked skid steering and surface slip cause error. Calibrate counts, direction, wheel/track geometry and velocity limits with the final payload on the intended surface.
Can it be used outdoors?
The suspension and tracks are suited to varied test surfaces, but no waterproof or weatherproof rating is claimed. Keep electronics and the lithium battery dry, and avoid uncontrolled public or hazardous environments.
What must I add for ROS 2 navigation?
Add a supported host computer, a safe host-to-motor-driver interface, regulated host power, sensors such as LiDAR/camera, transforms, calibration, navigation software and application-specific safety behavior.