 1 / 1
Cogalloy RRC Lite STM32 Robot Controller for Raspberry Pi 5
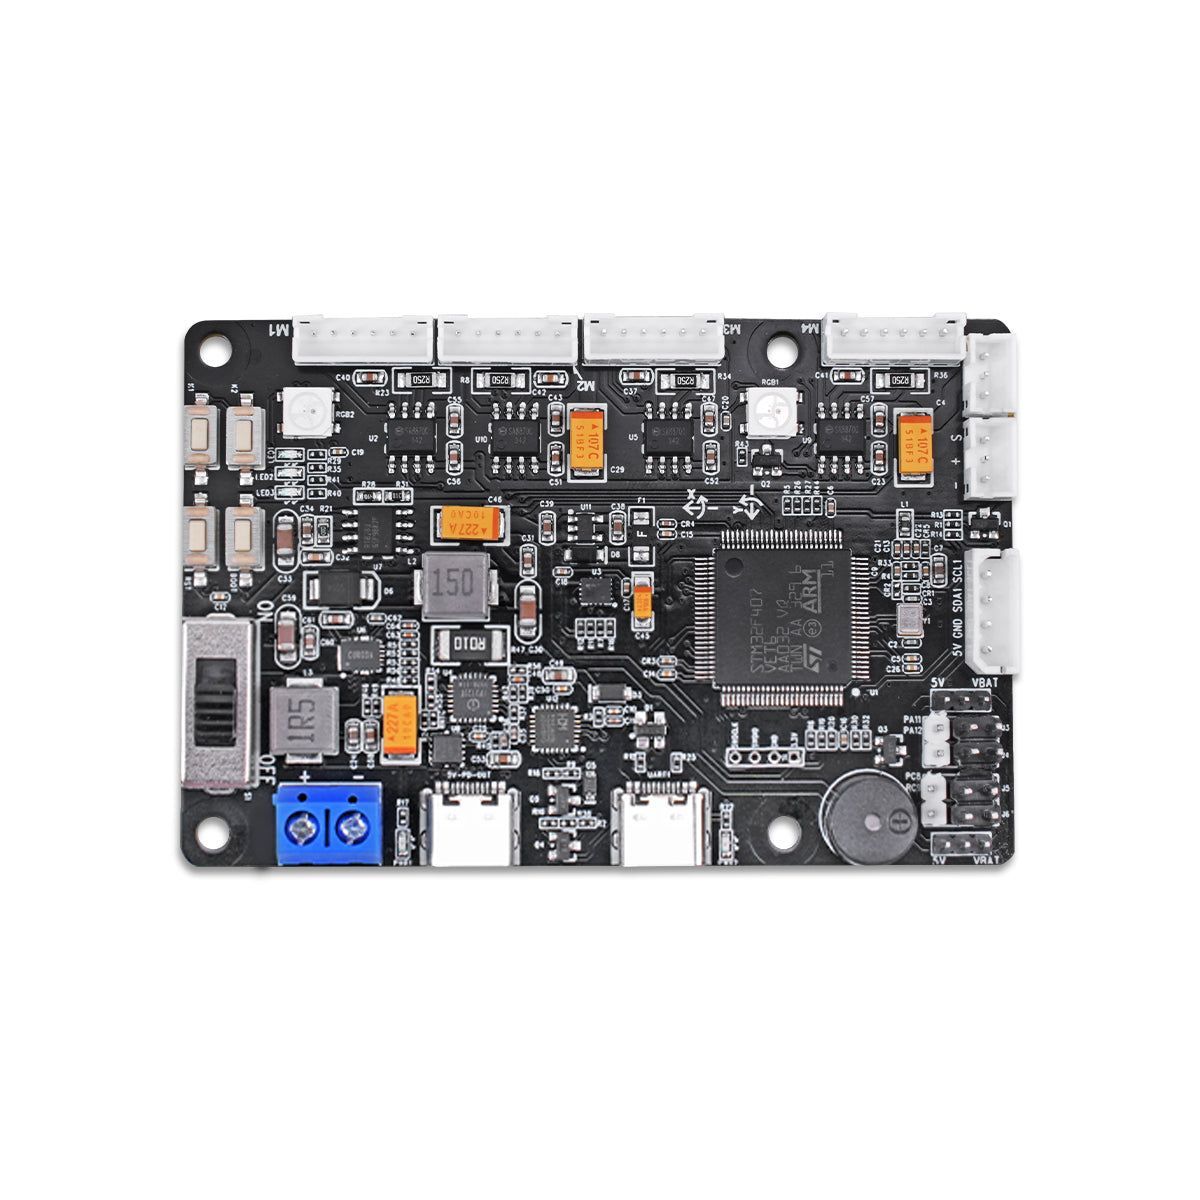
A real-time STM32F407VET6 control layer for Raspberry Pi 5 robots: four independent encoder-motor channels, QMI8658 6-axis IMU, PWM and serial-bus servo ports, USB/I²C, plus a Pi 5-compatible 5 V / 5 A host-power path. Base pack includes the board, a 1 m Type-C data cable and an accessory bag.
- Let Linux think; let STM32 close the loop: Keep ROS 2 and high-level workloads on the host while the controller handles timing-sensitive I/O, motion and feedback.
- Four encoder-motor channels with a clear port map: Plan the delivered motors, encoders, voltage and kinematics before commanding a differential, Mecanum, omnidirectional, steering or Ackermann chassis.
- Pi 5-compatible 5 V / 5 A host-power path: The board supports the Raspberry Pi 5 power-supply protocol; design the battery, wiring and heat budget for the complete robot.
- Build with evidence, not assumptions: Use the labelled interface layout, published mounting pattern and base-pack list to check integration before installation.
Price
US$39.99
No account or payment needed. We usually confirm availability, lead time, shipping, and total price within 12 hours.
Or email us directly: sales@cogalloy.comShipping options and final delivery cost are shown at checkout.
SYSTEM DESIGN
Give the Linux host and real-time controller distinct jobs.
Raspberry Pi 5 runs Linux, ROS 2 and high-level software. RRC Lite is the low-level motion, encoder, IMU and peripheral layer. This separation makes timing, integration and fault isolation more predictable.
- STM32F407VET6 Cortex-M4 at up to 168 MHz
- QMI8658 six-axis IMU for acceleration and angular-rate feedback
- Use the matched serial protocol and firmware as a system
PORT MAP
Connect the labelled interface—not a guessed equivalent.
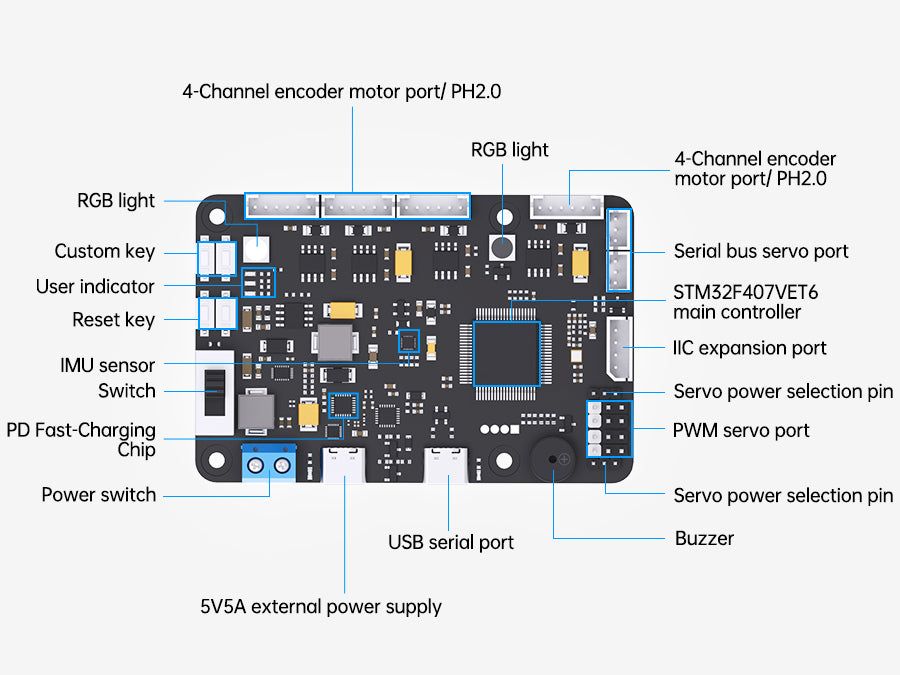
The board exposes four encoder-motor channels, four PWM-servo channels, two serial-bus-servo channels, USB serial, I²C and onboard indicators. Verify connector type, polarity, servo-voltage jumper and firmware mapping before connecting a load.
- 4 independent encoder-motor channels
- PWM servos: 4 channels at 5–8.4 V; serial-bus servos: 2 channels at 6–12 V
- USB serial and I²C for the confirmed host/peripheral arrangement
POWER PATH
Treat 5 V / 5 A as part of the finished robot design.
Feed the board with 6–14 V DC. Its 5 V / 5 A external output is compatible with the Raspberry Pi 5 power-supply protocol, but the battery, motor demand, cable gauge, fuse strategy, connectors and cooling still need system-level validation.
- 6–14 V DC input
- 5 V / 5 A external host-power path
- Commission polarity, power and motion with the wheels unloaded
FIT AND PACK
Check the mounting footprint and pack before you build.
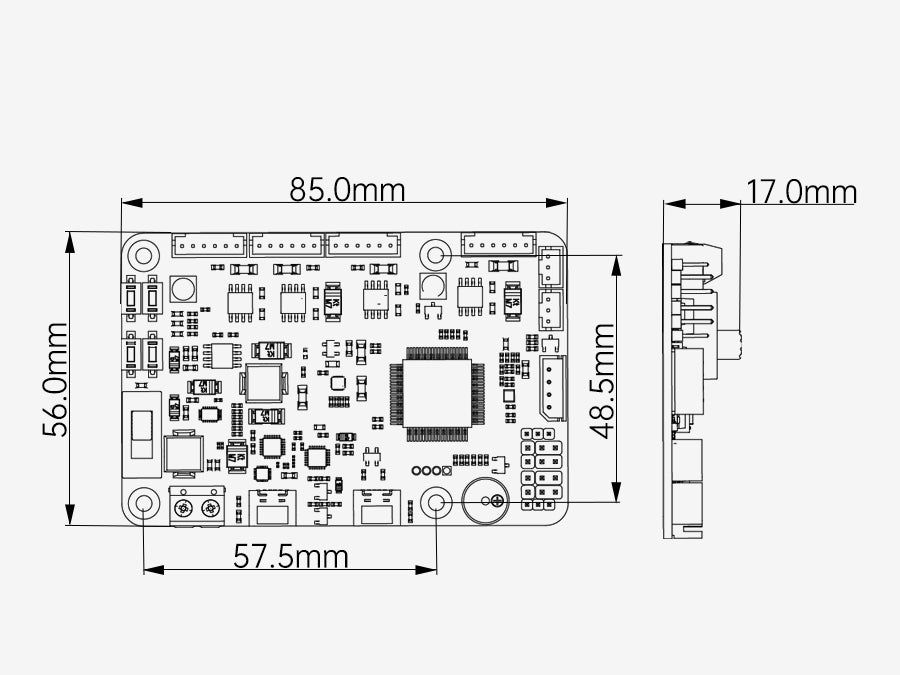
The 85 × 56 × 17 mm board has a 57.5 × 48.5 mm mounting-hole pitch. The base pack includes the controller, a one-metre Type-C data cable and an accessory bag; order any Raspberry Pi, battery, actuators and sensors separately unless explicitly included.
- Board footprint: 85 × 56 × 17 mm; mounting pitch: 57.5 × 48.5 mm
- Controller ×1, 1 m Type-C data cable ×1, accessory bag ×1
- Use the final order confirmation as the source of truth for optional hardware
Related tutorials
Build with your parts
 Beginner
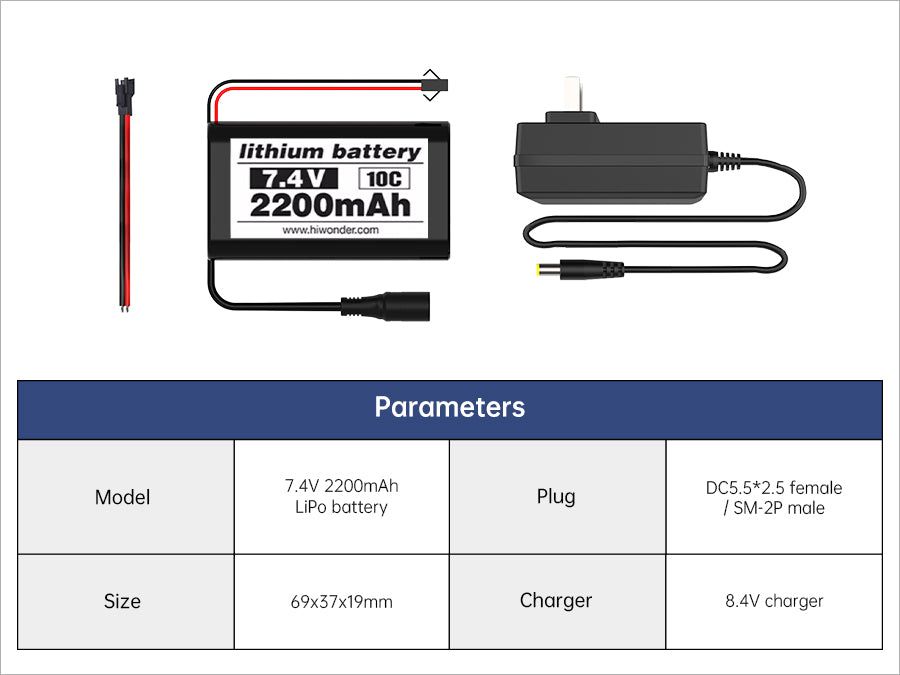
7.4 V 2200 mAh Battery Pack: Compatibility and Preflight
Confirm voltage, connectors, polarity and charge path before a 7.4 V battery pack becomes part of a robot power design.
Read tutorial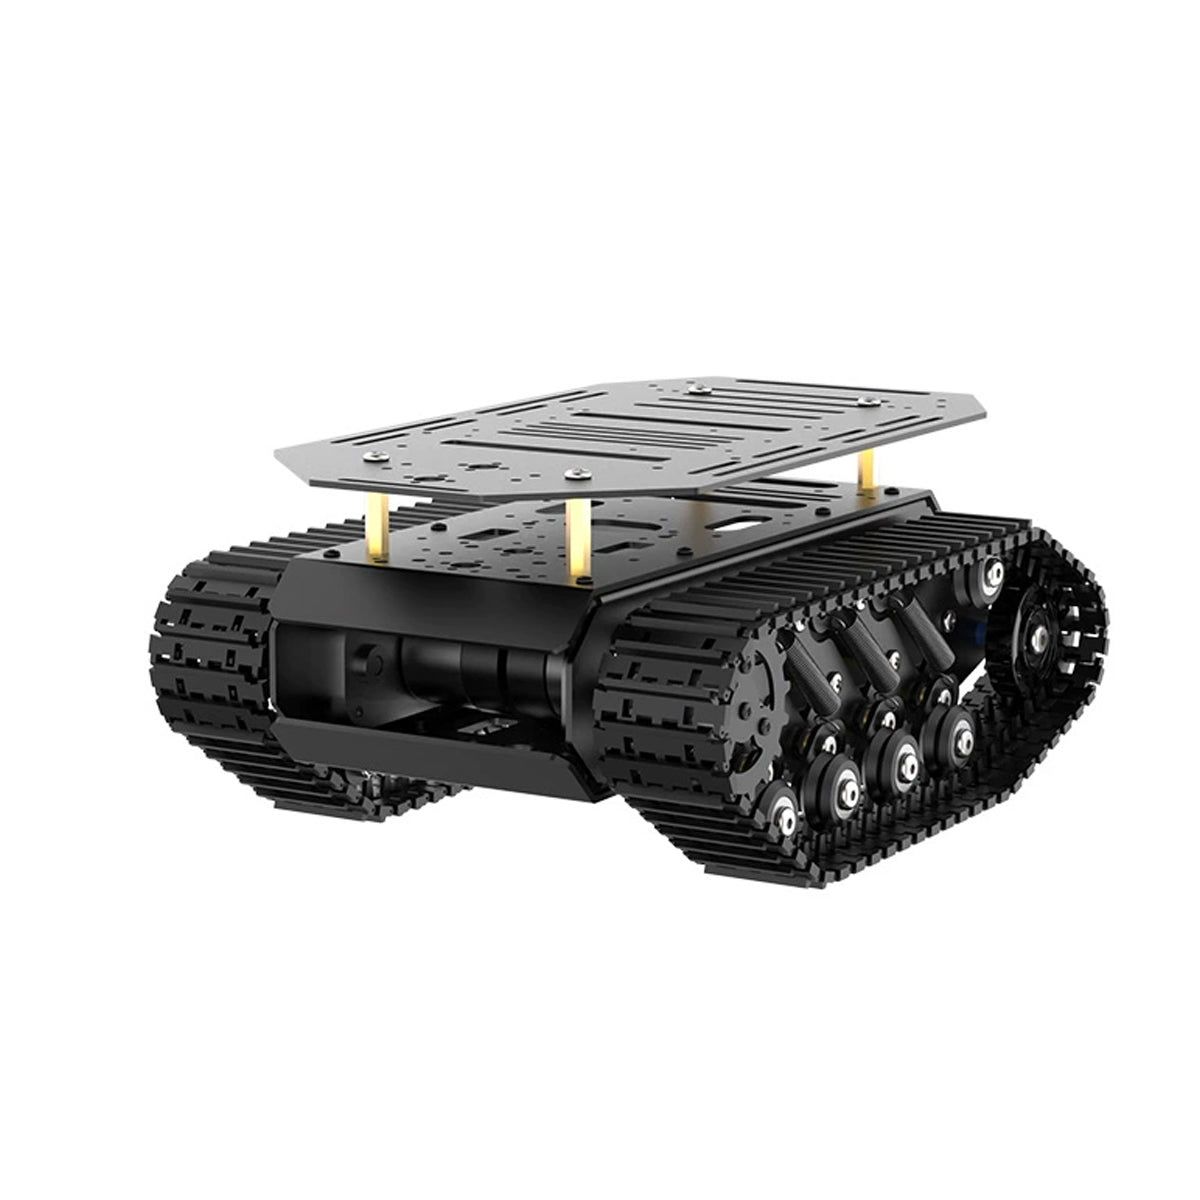 Beginner
Cogalloy T1 Advanced: Delivery, Power and Wiring Inspection
Inspect the delivered tracked chassis, its included 11.1 V battery system and all expansion wiring before the first powered test.
Read tutorialBeginnerRaspberry Pi 5 + RRC Lite: Your First ROS 2 Telemetry Node
Create a safe ROS 2 Python telemetry node before translating any serial data into motor or servo commands.
Read tutorialProduct details
Everything you need to evaluate the fit.
Clear product information, technical specifications and compatibility details—kept separate from the purchase decision.
Overview
A real-time control layer for a Raspberry Pi 5 robot
Cogalloy RRC Lite is an STM32F407VET6 controller for robot systems built around Raspberry Pi 5. Keep the responsibilities clear: the Linux host runs ROS 2, networking, vision and application logic; RRC Lite handles the time-sensitive motion, encoder, IMU, servo and peripheral work below it.
It is a low-level controller, not a Linux computer and not a general-purpose motor driver. Use the delivered board, matching firmware and documented wiring map as one system.
Motion, sensing and expansion
Four independent encoder-motor channels support the matched 2WD/4WD differential, Mecanum, omnidirectional, steering and Ackermann robot configurations. The board uses an STM32F407VET6 Cortex-M4 running at up to 168 MHz and includes a QMI8658 six-axis IMU for three-axis acceleration and angular-rate feedback.
For mechanisms and peripherals, it provides four PWM-servo channels, two serial-bus-servo channels, USB serial communication and I²C expansion. Motor, encoder, servo voltage, connector polarity and host protocol must all match the actual robot before power is applied.
Power is a system design decision
RRC Lite accepts 6–14 V DC and provides a 5 V / 5 A external host-power path compatible with the Raspberry Pi 5 power-supply protocol. This is not a promise that every battery, motor or cable combination is safe: calculate the finished robot's battery voltage, peak current, wire gauge, connector condition, fuse strategy and thermal behaviour.
The board is listed with reverse-polarity, over-current, over-temperature, short-circuit and backflow safeguards. Those safeguards supplement—never replace—correct wiring, a protected battery and a controlled commissioning process.
What the base pack actually includes
The base pack contains one RRC Lite controller, one 1 m Type-C data cable and one accessory bag. Raspberry Pi, battery, motors, encoders, servos, sensors and other robot hardware are not included unless the final order confirmation explicitly says otherwise.
Before allowing a chassis to move, check input polarity and voltage, the servo-voltage jumper, USB serial link, motor/encoder mapping and IMU orientation. Test direction at low speed with the wheels safely unloaded, and keep controller firmware aligned with the host software and physical robot configuration.
Technical specifications
IMU
QMI8658 6-axis IMU: three-axis accelerometer and three-axis gyroscope
Weight
32 g
Base pack
RRC Lite controller ×1, 1 m Type-C data cable ×1, accessory bag ×1
Dimensions
85 × 56 × 17 mm
Protection
Listed safeguards: reverse polarity, over-current, over-temperature, short circuit and backflow
Power input
6–14 V DC
Motor driver
SA8870C motor-drive stage with over-current protection
Real-time MCU
STM32F407VET6 (100-pin) Arm Cortex-M4, up to 168 MHz; 512 KB Flash, 192 KB SRAM, FPU/DSP
Firmware update
Serial-port one-click download; preserve a known-good matched image before customising firmware
PWM servo ports
4 channels, 5–8.4 V; select the correct servo supply using the onboard jumper
User indicators
Buzzer ×1, LED ×3 and RGB LED ×2
Product identity
Cogalloy RRC Lite STM32 robot controller for Raspberry Pi 5 robot systems
Board construction
Industrial-grade dual-layer board
Mounting-hole pitch
57.5 × 48.5 mm
Encoder-motor channels
4 independent channels; use only with the matched motor, encoder wiring and chassis firmware
Serial-bus servo ports
2 channels, 6–12 V
Host and peripheral I/O
USB serial communication and I²C expansion; confirm the supplied cable, pinout and protocol before connection
Not included by default
Raspberry Pi, battery, motors, encoders, servos, sensors and other robot hardware
Raspberry Pi 5 host-power path
External 5 V / 5 A output compatible with the Raspberry Pi 5 power-supply protocol
Shipping & support
Choose your destination at checkout to see the available shipping methods. Need integration advice before ordering? Our support team can help you choose compatible components.
In the box
Package contents
RRC Lite STM32 robot controller
Cogalloy RRC Lite controller board for Raspberry Pi 5 robot systems.
Type-C data cable
One-metre data cable supplied with the base pack.
Accessory bag
Supplied mechanical accessories for the controller; confirm the delivered contents before installation.
Host and robot hardware
Raspberry Pi, battery, motors, encoders, servos, sensors and other robot hardware are not included by default.
Expert support
Frequently asked questions
Does RRC Lite replace a Raspberry Pi 5?
No. RRC Lite is the low-level real-time controller. Raspberry Pi 5 or another compatible Linux host runs ROS 2, networking, vision and high-level application logic.
Can it power a Raspberry Pi 5?
It provides a 5 V / 5 A external output compatible with the Raspberry Pi 5 power-supply protocol. Power the controller only within the 6–14 V DC input range and validate the full battery, motor, cable and thermal budget on the finished robot.
Which chassis types can it support?
With the correct delivered motors, encoders, wiring map, firmware and kinematics, it can be used in matched 2WD/4WD differential, Mecanum, omnidirectional, steering and Ackermann configurations. It is not a universal plug-and-play guarantee.
Can I plug in any motor or servo?
No. Confirm driver limits, motor voltage, encoder pinout, servo-voltage jumper, connector polarity and matching firmware before connecting an actuator.
Can I load my own firmware?
The board supports serial-port firmware download. First save the known-good matched firmware and test changes safely with the wheels unloaded; custom firmware can change motor and power behaviour.
What does the base pack include?
One RRC Lite controller, one 1 m Type-C data cable and one accessory bag. Raspberry Pi, battery, motors, encoders, servos, sensors and other robot hardware are separate unless explicitly listed on the final order confirmation.
How should I bring the robot up safely?
Check input polarity and voltage, servo jumper, host link, port mapping and IMU orientation first. Test motor direction at low speed with wheels clear of the ground, then validate the complete system before normal operation.